CONTROLAgents & automation
Fusefly Stereoscopic Vision System

WebDevCody@webdevcody
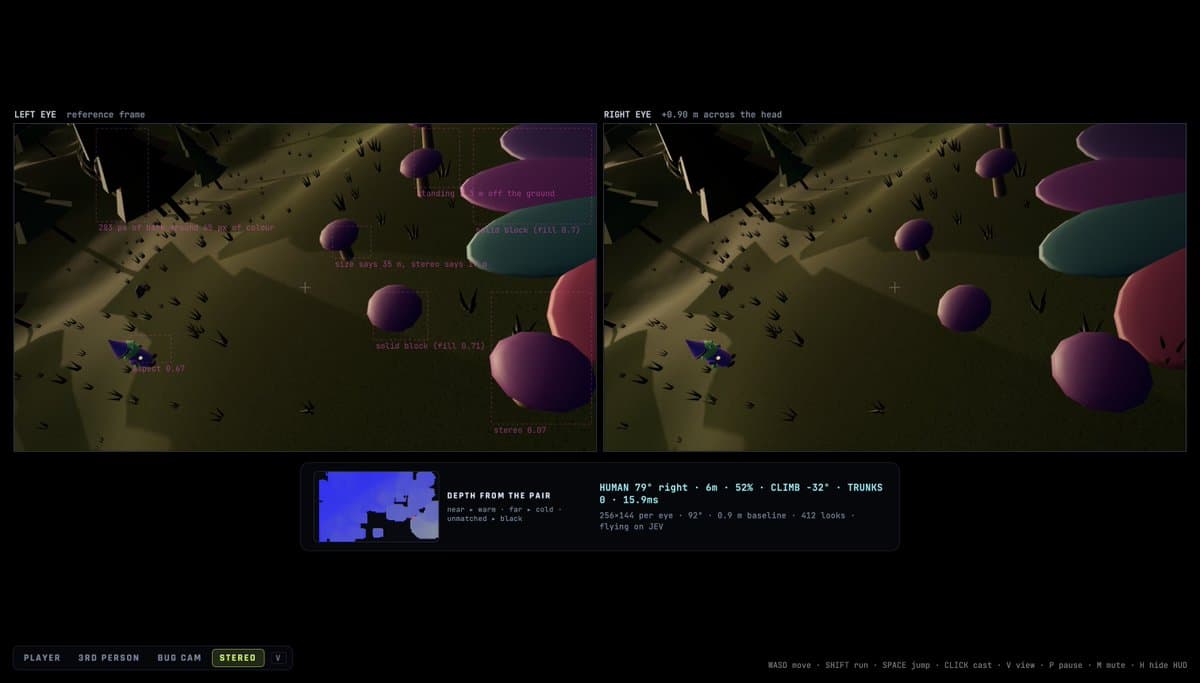
This project enhances the Fusefly's vision by implementing stereoscopic capabilities with two virtual cameras to generate a real-time depth map, which is then used alongside images for object detection and to feed perceived object distance and location into Jev for bug control.
I made the Fusefly's vision use stereoscopic vision, so two virtual camera on it which generate a depth map in real time and then uses the images and depth map to do object detection to then feed it's precieved object distance and location into Jev to control the bug. x.com/webdevcody/status/210154265648870607
Related builds